Line Detection
Introduction
This section teaches how to use OpenCV to detect line segments in an image.
Experiment Objective
Detect line segments in an image and draw them for display.
Experiment Explanation
The OpenCV Python library provides two line detection methods: HoughLines() for detecting straight lines (infinite) and HoughLinesP() for detecting line segments. This section primarily uses HoughLinesP(), which only supports binary grayscale images.
HoughLinesP() Usage
lines = cv2.HoughLinesP(image, rho, theta, threshold, minLineLength, maxLineGap)
Line segment detection. Returns lines as an array of all line segment coordinates. Example: [[x0,y0,x1,y1],[x0,y0,x1,y1]]
image: Original image. Must be a binary grayscale image.rho: Detection radius step size. The default value is 1, meaning all radius step sizes are detected.theta: Angle for detecting lines. The default value is π/180, meaning all angles are detected.threshold: Threshold; the smaller the value, the more detections.minLineLength: Minimum length. Line segments shorter than this length are not detected.maxLineGap: Minimum distance between line segments.
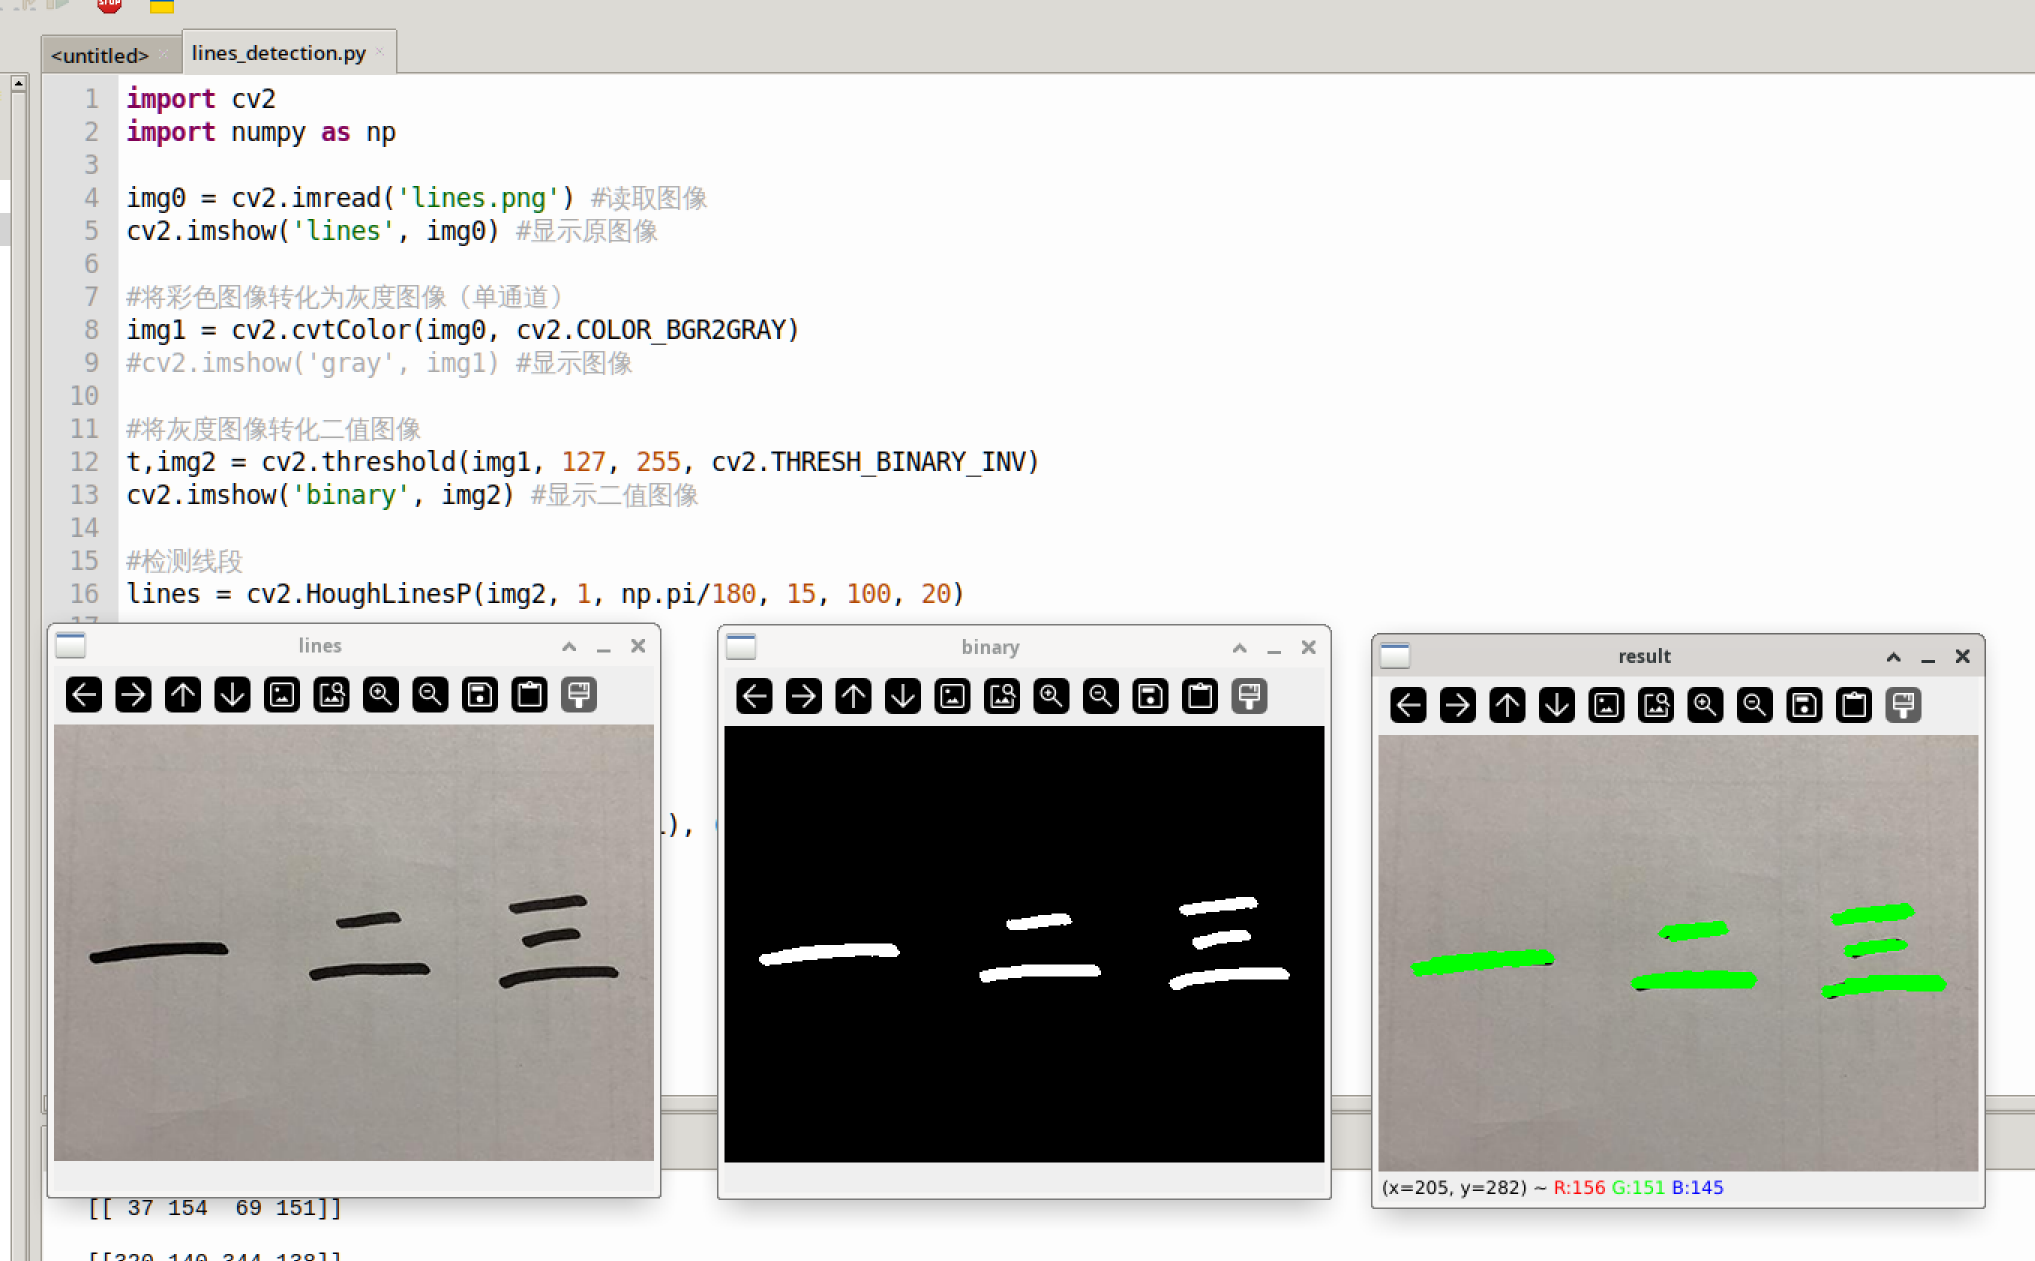
Read the image, convert it to a binary grayscale image, and then perform line segment detection. The code flow is as follows:
The reference code is as follows:
'''
Experiment Name: Line Detection
Experiment Platform: WalnutPi 1B
'''

import cv2
import numpy as np

img0 = cv2.imread('lines.png') # Read the image
cv2.imshow('lines', img0) # Display the original image

# Convert the color image to a grayscale image (single channel)
img1 = cv2.cvtColor(img0, cv2.COLOR_BGR2GRAY)
#cv2.imshow('gray', img1) # Display the image

# Convert the grayscale image to a binary image
t,img2 = cv2.threshold(img1, 127, 255, cv2.THRESH_BINARY_INV)
cv2.imshow('binary', img2) # Display the binary image

# Detect line segments
lines = cv2.HoughLinesP(img2, 1, np.pi/180, 15, 100, 20)

print(lines) # Print line segment information

# Draw line segments on the original image
for l in lines:
    x0, y0, x1, y1 = l[0]
    cv2.line(img0, (x0, y0), (x1, y1), (0,255,0), 3)

cv2.imshow('result', img0)

cv2.waitKey() # Wait for any keyboard key to be pressed
cv2.destroyAllWindows() # Close the window
Experiment Results
Run the above code on the WalnutPi; the experiment results are as follows: